
Graphite Flanged Thrust Bushings for Robot-Gripper Swivel Joints
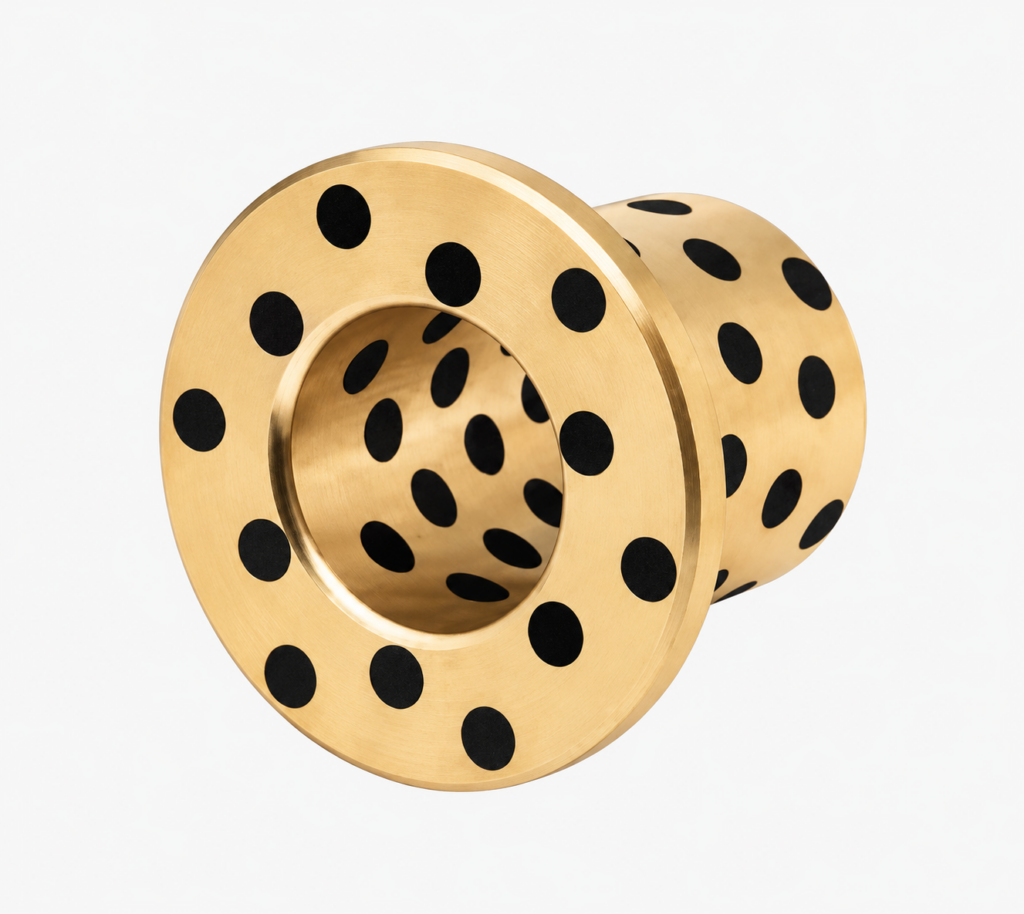
A gripper swivel or auxiliary tooling pivot can require radial guidance together with an axial sliding face in a short bearing stack. This enquiry covers an MPGZ/OFP01-style graphite-plugged flanged sleeve in a limited-angle tooling joint.
Size the radial sleeve and axial flange as separate contacts
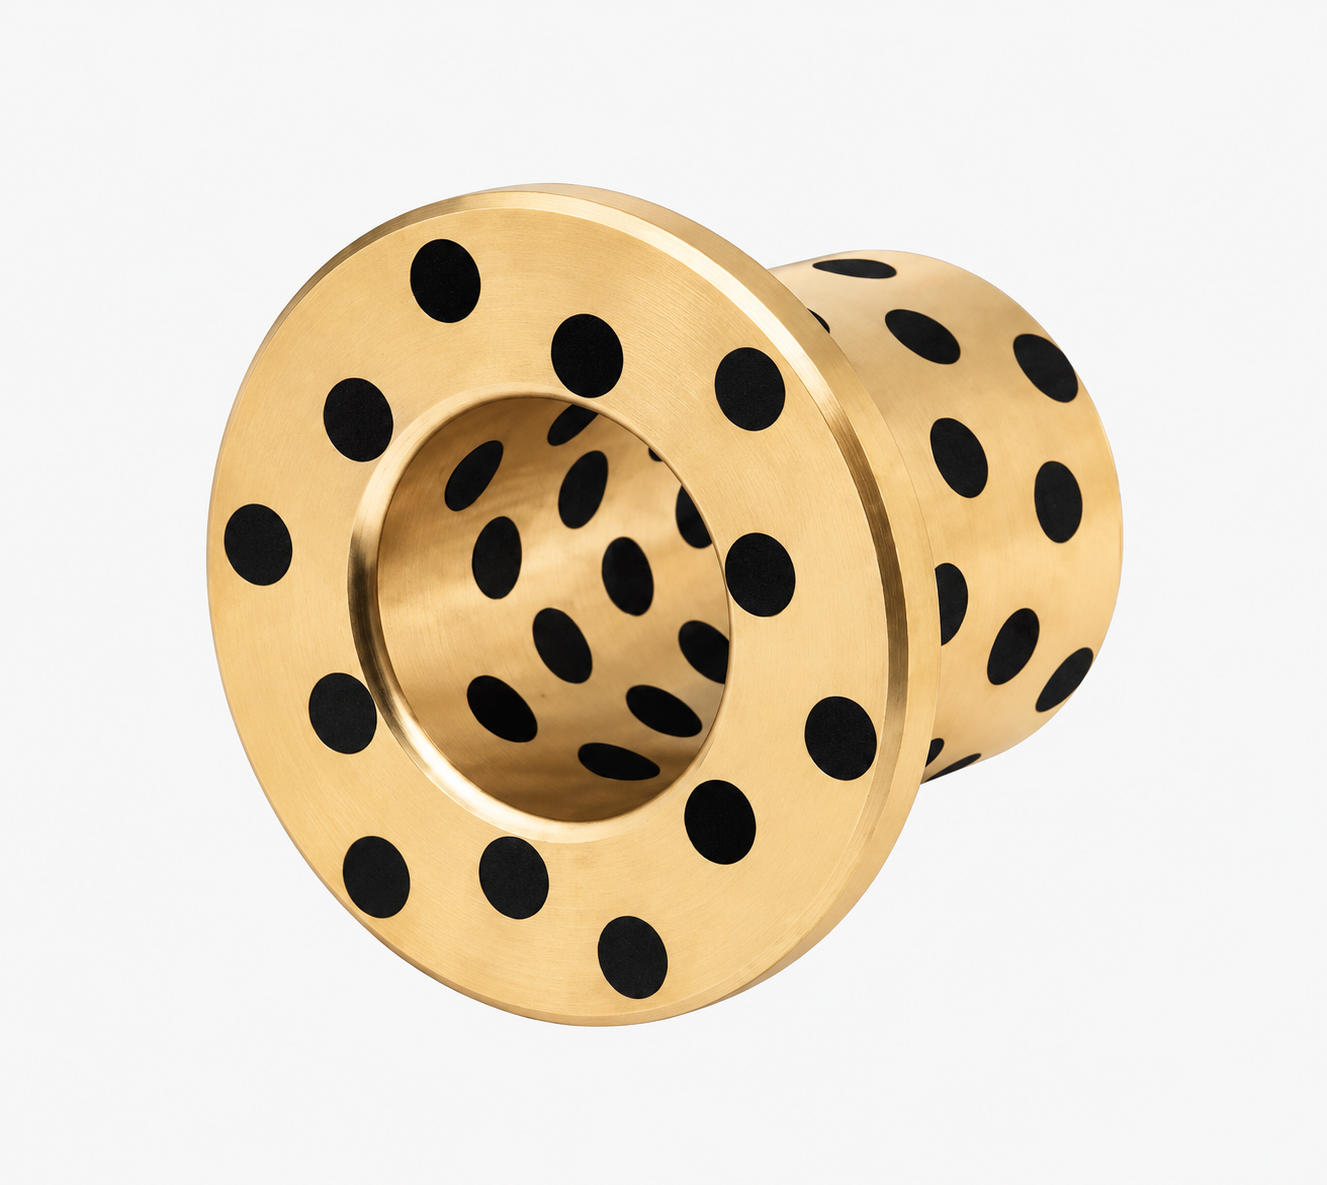
The cylindrical bore guides the pivot shaft while the flange face can support a drawing-defined thrust contact. Provide the actual thrust annulus and counterface geometry, not just the flange outside diameter. Define the retaining collar or shoulder and the allowable end play. A radial running fit does not establish axial preload or the torque required to move the gripper.
Operating conditions and selection boundaries
Supply tool mass, payload offset, acceleration, gripping reaction, articulation angle and cycle frequency. Identify whether the joint must hold a precise tool orientation or merely accommodate a secondary swivel. Breakaway torque, wear allowance and acceptable backlash need to be assessed for the actual mechanism.
This is a sliding-bearing option for a specified tooling joint. It does not establish robot positioning accuracy or replace a precision rotary bearing without an engineering review.
Specify the exact material standard, alloy or composite construction and any certificate requirements in the enquiry. Different national material designations are not treated as automatic equivalents. Availability and manufacturing details are confirmed in the quotation.
Dimensions and drawing information for quotation
| Drawing feature | Information to provide |
|---|---|
| Radial contact | Pin diameter, sleeve length, housing fit and load direction. |
| Thrust contact | Working annulus, counterface finish, flange thickness and end play. |
| Robot duty | Tool/payload mass, offsets, acceleration and gripping reaction. |
| Acceptance | Allowable swivel torque, angular play, inspection method and maintenance interval. |
Include quantity, units, drawing revision, inspection requirements and delivery destination. Distinguish measured wear from the intended new-part dimensions.
Installation and acceptance checks
Protect the graphite-plugged faces during pressing or fastening. Assemble the axial stack to the drawing-defined clearance and check motion under representative loading. Do not clamp the flange between faces in a way that unintentionally locks the swivel.
Confirm the lubrication and inspection plan for the specified material and duty. The application name does not establish a load rating, service-life guarantee or approval for the complete machine.
Frequently asked questions
Can the flange carry every gripper’s axial load?
The actual contact area and duty must be reviewed. No universal thrust rating is assigned here.
Is zero backlash available by tightening the collar?
Tightening can remove necessary running clearance and increase friction. Specify an approved bearing stack and acceptance limit.
What material should be requested?
State the required copper-alloy grade and graphite specification. Any alternative requires separate confirmation, not assumed grade equivalence.
Request a drawing-based quotation
Send the assembly section, component drawing, quantity and operating conditions for robot gripper swivel joint bushings. BONIU will review the geometry, material and installation requirements before confirming the quotation.